Change Language :
Stepper motor
How they work, applications and types
A stepper motor is an electric motor that rotates in controlled and precise increments. This makes it ideal for applications that require accurate, precise, and repeatable positioning and movement. Stepper motors are used in a large variety of applications within industries such as; automation, laboratory equipment and industrial machinery.
Stepper motors can easily control the rotational movement without necessarily requiring an encoder for position feedback. It is important to understand how stepper motors work, as well as their advantages and limitations in order for designers to be able to select the best motor for their application.
Stepper motor vs servo motor: choosing the right one
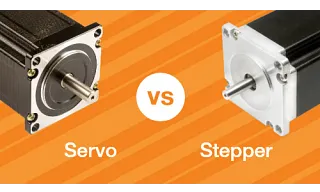
In engineering applications that require precise motion control, both servo motors and stepper motors are popular solutions. Both offer unique advantages that are suitable for different tasks. Choosing the right type of motor for your project is critical to ensure optimal performance and efficiency.
Things to consider:
- Precision requirements and motion type: Does your application require a high level of precision and accuracy? A stepper motor and a servo motor can be a good choice.
- Budget constraints: If costs play a major role and moderate precision is sufficient, a stepper motor may be best suited to your requirements.
- Complexity of control: If your team lacks experience with complex control systems, the stepper motor offers simpler implementation when using controllers such as the igus D1.
Function comparisons between servo and stepper motors
The choice between a servo motor and a stepper motor depends on the specific requirements of your application. Servo motors offer superior precision, speed and torque control. However, they are more expensive and require advanced expertise. Stepper motors are a cost-effective and easy-to-implement alternative, but with limitations in terms of speed and accuracy. By carefully analysing your project needs, you can make the right decision and achieve optimal results.
Browse stepper motor types
At igus® you will only find effective hybrid stepper motors. We always keep a large stock so that your desired motor is ready for dispatch within 24 hours.


Why choose igus® stepper motors?

All electric motors are 100% tested

No minimum order quantity

Shipping from 24hrs and consistently maintained stock

Long product life
Frequently asked questions
A stepper motor is a motor that moves in steps as opposed to continuously rotating like other types of motors.
A stepper motor works by energising its electromagnets in a controlled sequence, meaning its output shaft turns in small, fixed steps. Giving precisse control of its position and speed
The key difference is how they control movement, stepper motors use steps and servo motors tend to use feedback to adjust speed and position
Torque, speed, operating conditions, position accuracy and load, these are the main things to consider.
No, an encoder is not needed on all stepper motors.
Stepper motors usually operate in an open-loop system: the control system sends a command to move a certain number of steps. Generally, there is no feedback to confirm the actual position. Servo motors, on the other hand, use a closed-loop system with a feedback device. The control system continuously monitors the actual position and speed of the motor and adjusts the current to correct any deviations, thus ensuring high accuracy.
Stepper motors provide good torque at low speeds but tend to lose torque as speed increases. Servo motors operate at higher speeds and maintain torque more effectively across a wider speed range. Stepper motors are often more cost-effective and offer predictable positioning, while servo motors are better suited to applications requiring rapid acceleration and changing loads
Servo motors offer better positioning accuracy because they use feedback from an encoder to monitor. Stepper motors move in defined steps, can provide good positioning accuracy without feedback, but struggles with higher loads. Depending on the application's load, speed and accuracy requirements will depend on the best option.
Servo motors typically maintain positioning accuracy better under changing loads and at higher speeds because they use encoder feedback to detect and correct positioning errors. Stepper motors can provide accurate positioning without feedback when correctly sized for the application. The best choice depends on the load, speed and accuracy required.
Stepper motors are usually a more cost-effective option compared to servo motors.
A stepper motor is the better choice for applications requiring precise, repeatable positioning and cost is a consideration. It is suitable for predictable loads, low to moderate speeds and systems that need good holding torque without complex feedback control.
Typically, servo motors are more energy efficient in applications with changing loads, frequent movement or high speeds. Stepper motors, when used in open loop, often draw current even when stationary to maintain holding torque, which can generate heat and use more energy. However, the most efficient option will depend factors such as the motor, controller, load and operating conditions.
There are several ways, depending on the motor and controller. You can change the direction setting in the control software or change the signal to the driver’s DIR input. For a typical bipolar stepper motor, you can also swap the two wires of one coil, with the power switched off. Alternatively, if the controller firmware directly controls the coils, you can reverse the stepping sequence.
A stepper motor’s available torque depends on its speed, current and driver settings. Typically, you would use the manufacturer’s holding torque specification when the motor is stationary and energised, and its torque–speed curve when it is running. There is no single simple formula that accurately calculates its torque under all operating conditions.
Stepper motors are controlled with a controller which translates signals into electrical current sequences into the stepper motor. This energizes the magnets within the motor and creates rotational movement in the form of steps.
Compatible products for our electric motors


Consulting
I look forward to answering your questions
igus Australia1300 726 244Write e-mail
Shipping and consultation
In person:
Monday to Friday from 8 am - 5 pm.